Scholar
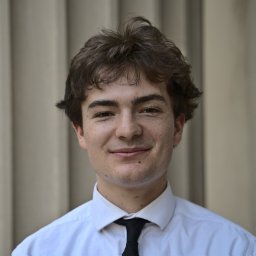
Michael Burgess
Google Scholar ID: tsr7VWAAAAAJ
Massachusetts Institute of Technology
Citations & Impact
Citations
8
H-index
2
i10-index
0
Publications
6
Co-authors
1
list available
Publications
Resume
Academic Achievements
- Worked on multiple interdisciplinary projects including complex fluids research, challenging mechanical design problems, and software development. All notable projects are showcased in his portfolio.
Research Experience
- - Working as an applied scientist at RAI Institute, developing effective perception and control pipelines for an agile manipulation platform
- - Conducted research on high-resolution tactile sensing in the Perceptual Science Group at MIT, developed algorithms for estimating the compliance of grasped objects, and created a set of fingers designed for a wide array of manipulation tasks
- - Worked as a research assistant in the Biomimetic Robotics Lab at MIT, studying how to generate high-level trajectories for a quadruped robot across complex, discrete terrain
Education
- - Master's degree: MIT, Advisor: Prof. Ted Adelson, Focus: High-resolution tactile sensing
- - Bachelor's degree: MIT, Advisor: Prof. Sangbae Kim, Focus: Trajectory generation for quadruped robots
Background
- Roboticist, graduated from MIT, currently working as an applied scientist at RAI Institute. Research interests include high-resolution tactile sensing and the development of perception and control pipelines for dynamic actions.
Miscellany
- Originally from seacoast New Hampshire, now located in the Cambridge/Boston area. In his free time, he loves to play guitar, skateboard, and paint.
