Scholar
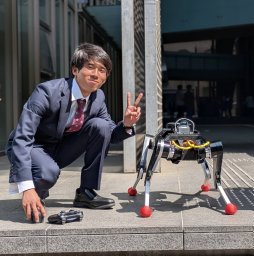
Keita Yoneda
Google Scholar ID: y9ox02kAAAAJ
PhD Student, JSK Robotics Laboratory, The University of Tokyo
Citations & Impact
Citations
0
H-index
0
i10-index
0
Publications
5
Co-authors
0
Contact
Publications
Resume
Academic Achievements
- Published a paper titled 'KLEIYN: A Quadruped Robot with an Active Waist for Both Locomotion and Wall Climbing' at the 2025 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS).
- Presented research on achieving standing up and bipedal walking using the quadruped robot KLEIYN based on reinforcement learning at the 43rd Annual Conference of the Robotics Society of Japan (RSJ25J).
- Reported findings on realizing walking and wall climbing actions via reinforcement learning for the quadruped robot KLEIYN at ROBOMECH25J.
- Also presented work on controlling multiple small flying anchors using an RGB-D camera in wire-driven robots connected to the environment at ROBOMECH25J.
- Showcased a hexapod robot design featuring elastic legs and demonstrated face-to-wall climbing through reinforcement learning at RSJ24J.
Research Experience
- Involved in several research projects related to the quadruped robot KLEIYN, including the realization of standing up and bipedal walking, as well as reinforcement learning-based walking and wall climbing.
Education
- A PhD student at JSK Robotics Laboratory, The University of Tokyo.
Background
- Research Interests: Quadruped Robot, Reinforcement Learning, Bioinspired Mechanism, Multi-modal locomotion.