Scholar
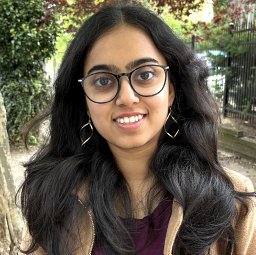
Sharanya Puthige Venkatesh
Google Scholar ID: jSHp1F0AAAAJ
University of Pennsylvania
Citations & Impact
Citations
2
H-index
1
i10-index
0
Publications
2
Co-authors
4
list available
Resume
Research Experience
- Researching contact-rich manipulation at the DAIR Lab; previously worked on medical devices.
Education
- MS in Robotics from GRASP, University of Pennsylvania, advised by Dr. Michael Posa; BTech in Biomedical Engineering from Manipal Institute of Technology.
Background
- Biomedical engineer turned roboticist. Focused on online optimal control algorithms and motion planning, with an interest in dexterous manipulation for humanoids.
Miscellany
- Seeking full-time robotics software engineering roles.