Scholar
Kunio Kojima
Google Scholar ID: 9W17PD0AAAAJ
The University of Tokyo
Humanoid Robots
Mechanical Design
Follow
Homepage
↗
Google Scholar
↗
Citations & Impact
All-time
Citations
509
H-index
11
i10-index
15
Publications
20
Co-authors
13
list available
Publications
2 items
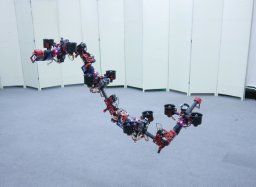
A Morphing Aerial Robot With Thruster-Integrated Flexible Continuum Links for Shape Adaptive Aerial Manipulation
2026
Cited
0
Flexible Morphing Aerial Robot with Inflatable Structure for Perching-based Human-Robot Interaction
2025
Cited
0
Co-authors
5 total
Masayuki Inaba
The University of Tokyo
Kei Okada
The University of Tokyo
Iori Kumagai
National Institute of Advanced Industrial Science and Technology (AIST)
Moju Zhao
university of tokyo, DRAGON Lab
Takuzumi Nishio
The University of Tokyo