Scholar
Moju Zhao
Google Scholar ID: 4P-VLNAAAAAJ
university of tokyo, DRAGON Lab
Robotics
Aerial Robotics
Motion Control
Motion Planning
Computer Vision
Follow
Homepage
↗
Google Scholar
↗
Citations & Impact
All-time
Citations
1,241
H-index
19
i10-index
30
Publications
20
Co-authors
19
list available
Contact
GitHub
Open ↗
Publications
15 items
Effector-Centric NMPC of Tiltable-Multirotors for Offset-Free Omnidirectional Aerial Manipulation
2026
Cited
0
Hybrid Impedance-Admittance Control with Multi-Link Aerial Robot for Contact-Rich Surface Sliding Task
2026
Cited
0
CoFL-S: Spatially Queryable Sector Flow Fields for Local Language-Conditioned Navigation
2026
Cited
0
Self-assembling Modular Aerial Robot for Versatile Aerial Tasks
2026
Cited
0
Energy-based Regularization for Learning Residual Dynamics in Neural MPC for Omnidirectional Aerial Robots
2026
Cited
0
CoFL: Continuous Flow Fields for Language-Conditioned Navigation
2026
Cited
0
Design, Modeling and Direction Control of a Wire-Driven Robotic Fish Based on a 2-DoF Crank-Slider Mechanism
2026
Cited
0
Hierarchical Trajectory Planning of Floating-Base Multi-Link Robot for Maneuvering in Confined Environments
2026
Cited
0
Load more
Resume
Academic Achievements
Three papers accepted to ICRA 2025 (January 2025)
One paper accepted to IEEE RA-L (August 2024)
One paper accepted to IEEE ICMA 2024 (August 2024)
Delivered a keynote talk at IEEE ROBIO 2023 (December 2023)
Research on 'Aerial-Terrestrial Hybrid Robot SPIDAR' featured in IEEE Spectrum (February 2023)
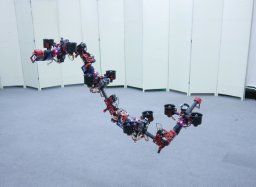
Research on 'Aerial Dragon Robot Reconfigures Itself Into a Flying Manipulator' featured in IEEE Spectrum (September 2022)
Co-authors
13 total
Masayuki Inaba
The University of Tokyo
Kei Okada
The University of Tokyo
Fan Shi
Assistant Professor in National University of Singapore
Xiangyu Chen
IO-AI.tech
Takuzumi Nishio
The University of Tokyo
Junichiro Sugihara
Ph.D. student, DRAGON Lab, The University of Tokyo,
Kazuki Sugihara
The University of Tokyo
Masaki Murooka
National Institute of Advanced Industrial Science and Technology